To be added soon
Residual Learning-Based Output Dynamics Control of an Underactuated Suspended Aerial Manipulator
Under review
Here you can find my Google Scholar profile.
Under review
Under review
In preparation
In preparation
In IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026
@inproceedings{das2026energy,
  title     = {Energy-based Swing-up and Grasping Maneuver using Suspended Aerial Manipulator},
  author    = {Das, Hemjyoti and Deimel, Stefan and Ott, Christian},
  booktitle = {2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
  year      = {2026}
}
In IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2025
@inproceedings{das2025partial,
  title     = {Partial Feedback Linearization Control of a Cable-Suspended Multirotor Platform for Stabilization of an Attached Load},
  author    = {Das, Hemjyoti and Ott, Christian},
  url       = {http://dx.doi.org/10.1109/IROS60139.2025.11246409},
  booktitle = {2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
  pages     = {21213–21220},
  publisher = {IEEE},
  year      = {2025}
}
In IFAC-PapersOnLine, 2025
@article{das2025learning,
  title     = {Learning Swing-up Maneuvers for a Suspended Aerial Manipulation Platform in a Hierarchical Control Framework},
  author    = {Das, Hemjyoti and Vu, Minh Nhat and Ott, Christian},
  url       = {http://dx.doi.org/10.1016/j.ifacol.2025.10.207},
  journal   = {IFAC-PapersOnLine},
  volume    = {59},
  number    = {18},
  pages     = {121–126},
  publisher = {Elsevier BV},
  year      = {2025},
  ISSN      = {2405-8963}
}
In IEEE Transactions on Automation Science and Engineering (T-ASE), 2025
@article{das2025whole,
  title     = {Whole-Body Stabilization of a Cable-Suspended Multirotor Platform Carrying a Slung Load},
  author    = {Das, Hemjyoti and Zambella, Grazia and Ott, Christian},
  url       = {http://dx.doi.org/10.1109/TASE.2025.3588767},
  journal   = {IEEE Transactions on Automation Science and Engineering},
  volume    = {22},
  pages     = {22337–22355},
  publisher = {Institute of Electrical and Electronics Engineers (IEEE)},
  year      = {2025},
  ISSN      = {1558-3783}
}
In IEEE International Conference on Robotics and Automation (ICRA), 2024
@inproceedings{das2024observer,
  title     = {Observer-based Controller Design for Oscillation Damping of a Novel Suspended Underactuated Aerial Platform},
  author    = {Das, Hemjyoti and Vu, Minh Nhat and Egle, Tobias and Ott, Christian},
  url       = {http://dx.doi.org/10.1109/ICRA57147.2024.10610305},
  booktitle = {2024 IEEE International Conference on Robotics and Automation (ICRA)},
  pages     = {8415–8421},
  publisher = {IEEE},
  year      = {2024}
}

In IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2023
@inproceedings{das2023hardware,
  title     = {Hardware-in-the-Loop Simulation of Vehicle-Manipulator Systems for Physical Interaction Tasks},
  author    = {Das, Hemjyoti and Sæbø, Bjørn Kåre and Pettersen, Kristin Y. and Ott, Christian},
  url       = {http://dx.doi.org/10.1109/IROS55552.2023.10342250},
  booktitle = {2023 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
  pages     = {4390–4396},
  publisher = {IEEE},
  year      = {2023}
}

In IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2022
@inproceedings{corsini2022nonlinear,
  title     = {Nonlinear Model Predictive Control for Human-Robot Handover with Application to the Aerial Case},
  author    = {Corsini, Gianluca and Jacquet, Martin and Das, Hemjyoti and Afifi, Amr and Sidobre, Daniel and Franchi, Antonio},
  url       = {http://dx.doi.org/10.1109/IROS47612.2022.9981045},
  booktitle = {2022 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
  pages     = {7597–7604},
  publisher = {IEEE},
  year      = {2022}
}
In IEEE Robotics and Automation Letters, 2022
@article{jacquet2022motor,
  title     = {Motor-Level N-MPC for Cooperative Active Perception With Multiple Heterogeneous UAVs},
  author    = {Jacquet, Martin and Kivits, Max and Das, Hemjyoti and Franchi, Antonio},
  url       = {http://dx.doi.org/10.1109/LRA.2022.3143218},
  journal   = {IEEE Robotics and Automation Letters},
  volume    = {7},
  number    = {2},
  pages     = {2063–2070},
  publisher = {Institute of Electrical and Electronics Engineers (IEEE)},
  year      = {2022},
  ISSN      = {2377-3774}
}

In European Control Conference (ECC), 2021
@inproceedings{das2021incremental,
  title     = {Incremental Nonlinear Dynamic Inversion Control of Long-Stroke Pneumatic Actuators},
  author    = {Das, Hemjyoti and Pool, Daan and Kampen, Erik-Jan van},
  url       = {http://dx.doi.org/10.23919/ECC54610.2021.9654927},
  booktitle = {2021 European Control Conference (ECC)},
  pages     = {978–983},
  publisher = {IEEE},
  year      = {2021}
}
In IFAC-PapersOnLine, 2018
@article{das2018dynamic,
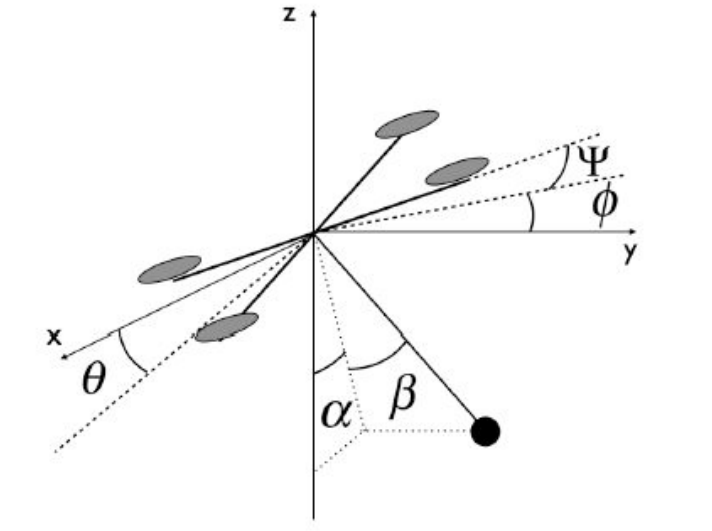
  title     = {Dynamic Inversion Control of Quadrotor with a Suspended Load},
  author    = {Das, Hemjyoti},
  url       = {http://dx.doi.org/10.1016/j.ifacol.2018.05.030},
  journal   = {IFAC-PapersOnLine},
  volume    = {51},
  number    = {1},
  pages     = {172–177},
  publisher = {Elsevier BV},
  year      = {2018},
  ISSN      = {2405-8963}
}

In IFAC-PapersOnLine, 2018
@article{das2018bioinspired,
  title     = {Bio-inspired Landing of Quadrotor using Improved State Estimation},
  author    = {Das, Hemjyoti and Sridhar, Kaustubh and Padhi, Radhakant},
  url       = {http://dx.doi.org/10.1016/j.ifacol.2018.05.078},
  journal   = {IFAC-PapersOnLine},
  volume    = {51},
  number    = {1},
  pages     = {462–467},
  publisher = {Elsevier BV},
  year      = {2018},
  ISSN      = {2405-8963}
}
In Soft Computing Applications: Proceedings of the 7th International Workshop Soft Computing Applications, 2017
@inbook{das2017fuzzy,
  title     = {Experimental Implementation of Fuzzy Vision-Based Tracking Control of Quad-Rotor},
  author    = {Das, Hemjyoti and Mazumdar, Aniket Samrat and Dey, Rajeeb and Roy, Lintu},
  url       = {http://dx.doi.org/10.1007/978-3-319-62524-9_24},
  booktitle = {Soft Computing Applications},
  pages     = {297–313},
  publisher = {Springer International Publishing},
  year      = {2017},
  ISSN      = {2194-5365},
  ISBN      = {9783319625249}
}
In International Conference on Control, Instrumentation, Communication and Computational Technologies (ICCICCT), 2016
@inproceedings{das2016static,
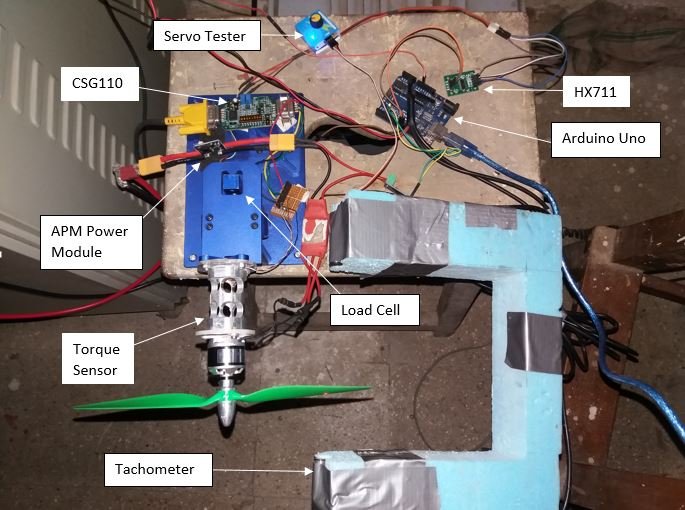
  title     = {Static performance analysis of electric propulsion system in quadrotors},
  author    = {Das, Hemjyoti and Baskaran, Venkatesh and Arya, Hemendra},
  url       = {http://dx.doi.org/10.1109/ICCICCT.2016.7988001},
  booktitle = {2016 International Conference on Control, Instrumentation, Communication and Computational Technologies (ICCICCT)},
  pages     = {495–500},
  publisher = {IEEE},
  year      = {2016}
}
In International Conference on Control, Instrumentation, Communication and Computational Technologies (ICCICCT), 2016
@inproceedings{das2016comparative,
  title     = {A comparative study between a cant angle hexacopter and a conventional hexacopter},
  author    = {Das, Hemjyoti},
  url       = {http://dx.doi.org/10.1109/ICCICCT.2016.7988002},
  booktitle = {2016 International Conference on Control, Instrumentation, Communication and Computational Technologies (ICCICCT)},
  pages     = {501–506},
  publisher = {IEEE},
  year      = {2016}
}